In humanoid robots, large joint actuators drive key motion areas such as the shoulders, elbows, waist, hips, and knees. As robots become more dynamic, compact, and powerful, heat management inside these joints becomes increasingly critical. During jumping, sudden stops, rapid turns, or continuous operation, heat can build up quickly inside the actuator. If this heat is not monitored in time, it may lead to control drift, insulation aging, magnet demagnetization, lubrication failure, joint malfunction, or system shutdown.
Reliable temperature sensing is therefore essential for stable robot operation.
1. Where Does the Heat Come From?
Heat inside a humanoid robot joint actuator mainly comes from three areas: the motor, the gearbox/reducer, and the drive module. The principle is simple: not all input energy becomes useful motion. Part of the energy is lost through electrical resistance, magnetic field changes, mechanical friction, and power device switching. These losses are eventually converted into heat and accumulate inside the compact actuator.
Typical heat sources include:
- Motor losses: winding resistance, magnetic losses, bearing friction.
- Gearbox losses: gear friction, bearing rotation, lubricant shear.
- Drive module losses: MOSFET switching and conduction losses.
That is why real‑time monitoring of these heat sources is the foundation of joint thermal management.
2. How Is Heat Transferred Out?
Heat dissipation inside the actuator happens in two stages.
First, heat must travel from the internal heat sources, such as windings, iron cores, and power devices, to the outer shell or heat dissipation structure. The goal is to reduce thermal resistance so heat can reach the surface faster.
Second, the heat must be released into the environment through air convection, radiation, or liquid cooling. This stage focuses on improving heat exchange efficiency so the system can dissipate heat continuously and stably.
So thermal management is not only about cooling. It also requires accurate temperature detection and fast feedback to the control system.
3. Why Are Temperature Sensors Critical?
In humanoid robot joints, temperature sensors do more than measure temperature. They support the control system by providing real‑time data for:
- Thermal compensation.
- Intelligent load reduction.
- Over‑temperature protection.
- Predictive maintenance.
This helps the robot maintain stable operation during high‑load movement.
However, robot joints often involve high‑frequency vibration, limited installation space, and long operating cycles. Standard temperature sensors may suffer from structural damage or performance drift. Traditional glass‑encapsulated NTC thermistors offer good resistance to heat, humidity, and corrosion, but stress can concentrate at the glass‑to‑lead junction. Under vibration, thermal cycling, or mechanical shock, this may cause glass cracking, loose leads, sealing degradation, or resistance drift.
Therefore, humanoid robot joint sensing requires not only accuracy, but also long‑term structural reliability.
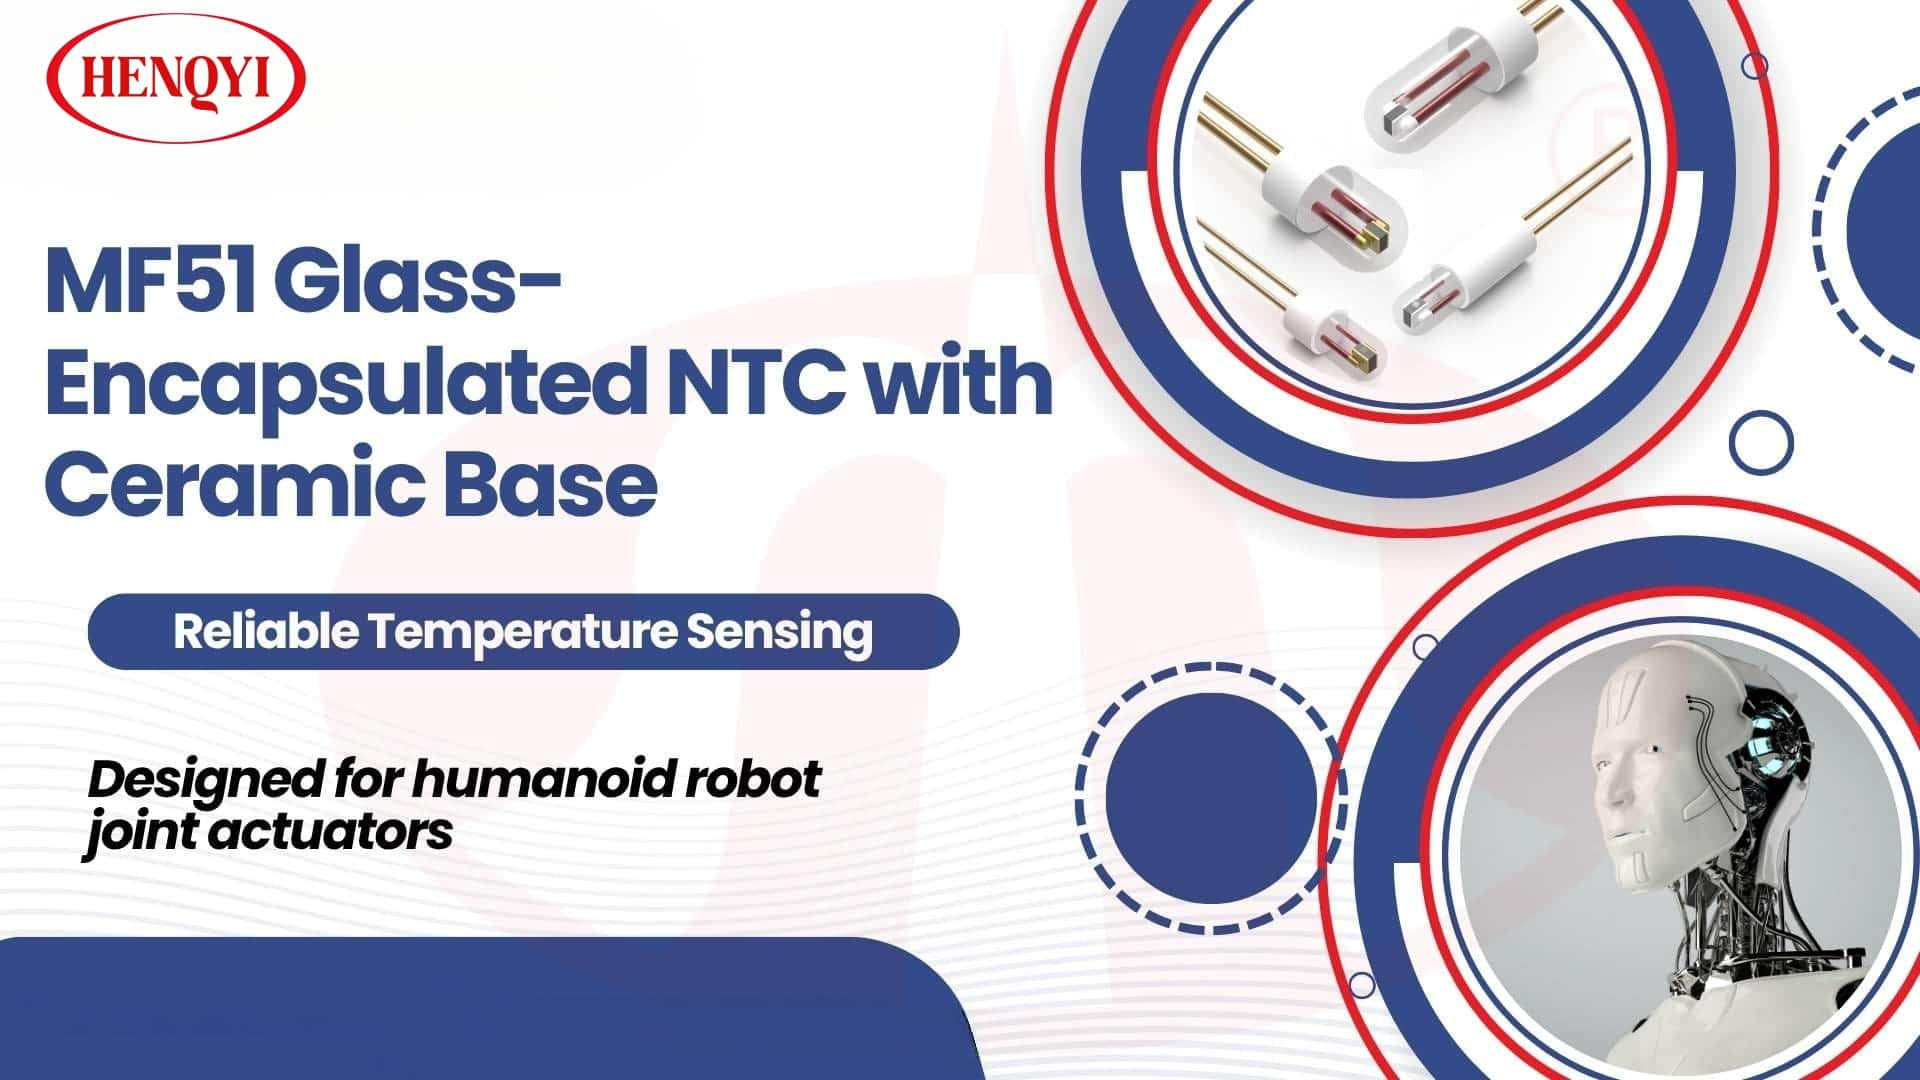
4. Why MF51 Glass‑Encapsulated NTC with Ceramic Base?
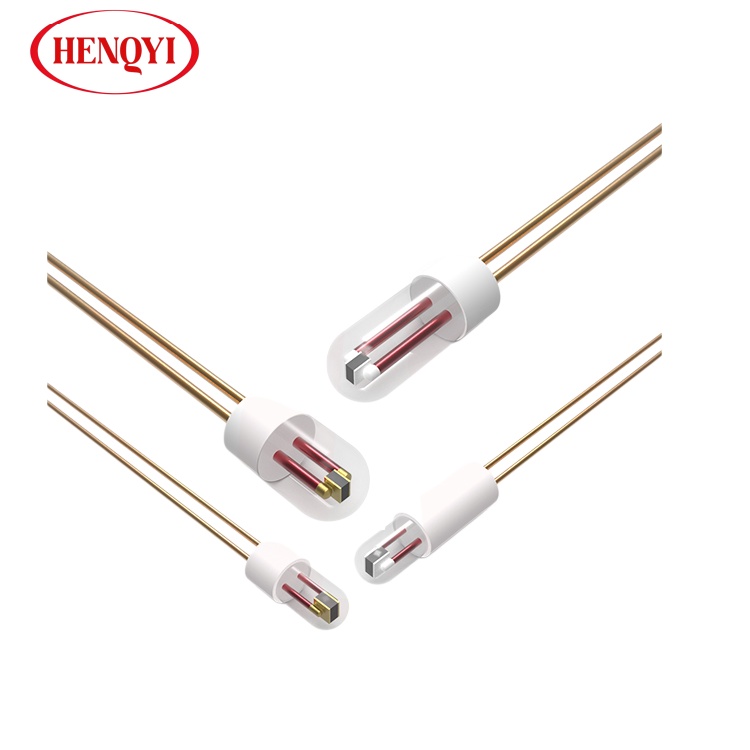
The MF51 glass‑encapsulated NTC thermistor with ceramic base is designed for harsh actuator environments.
Its composite structure combines glass encapsulation and ceramic base support. The glass structure provides stability in high temperature, humidity, and corrosive environments, while the ceramic base reinforces the connection between the glass body and lead wires.
This helps reduce stress concentration and improves mechanical reliability.
Key advantages include:
- Better vibration and shock resistance.
- Improved sealing and insulation stability.
- Compact design for confined robot joints.
- Suitable for long‑term continuous operation.
Reliable use in humidity, oil contamination, dust, and complex environments
5. Application Points in Humanoid Robot Joints.
MF51 can be installed at key temperature sensing points inside the actuator:
-
Motor housing surface
Monitors the overall temperature rise of the motor and indirectly reflects the thermal condition of windings and the iron core.
-
Outer side of stator winding ends
Placed closer to the main heat source, it captures winding temperature changes faster and supports thermal compensation and over‑temperature protection.
-
Near the drive module
Monitors the temperature of power devices such as MOSFETs, helping the system trigger load reduction, alarms, or protection actions in time.
Conclusion
Thermal management in humanoid robot joints depends not only on heat dissipation design, but also on accurate and reliable temperature monitoring.
The MF51 glass‑encapsulated NTC thermistor (temperature sensors) with ceramic base improves the reliability of traditional glass‑encapsulated NTCs in high‑vibration, confined, and complex environments. It provides a stable temperature sensing solution for humanoid robot joint actuators.
Reliable temperature sensing is the basis for safe motion, stable control, and long‑term robot performance.
SHENZHEN HENQYI offers customized MF51 series glass‑encapsulated NTC thermistors for humanoid robot joint actuator temperature measurement requirements.